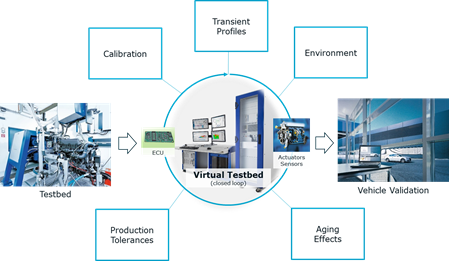
This course covers simulation frameworks for validating and
testing autonomous driving functions across the system
development V-model. It details the development workflows and
practical applications of Model-in-the-Loop (MIL), Software-in
the-Loop (SIL), and Hardware-in-the-Loop (HIL) simulation,
supported by illustrative examples including Driver-in-the-Loop
(DIL) and Vehicle-in-the-Loop (VIL) methodologies.
This course introduces testing environments, certification systematics, and accreditation frameworks for autonomous vehicles. It explores virtual and real-world test scenario design, compliance with ISO 34502 and PAS 1883 standards, and validation of core ADAS/AD functions including ACC, AEB, ALKS, and LKAS using CARLA simulator integration.